All projects
  • Hardware
  • Firmware

Camera control robot

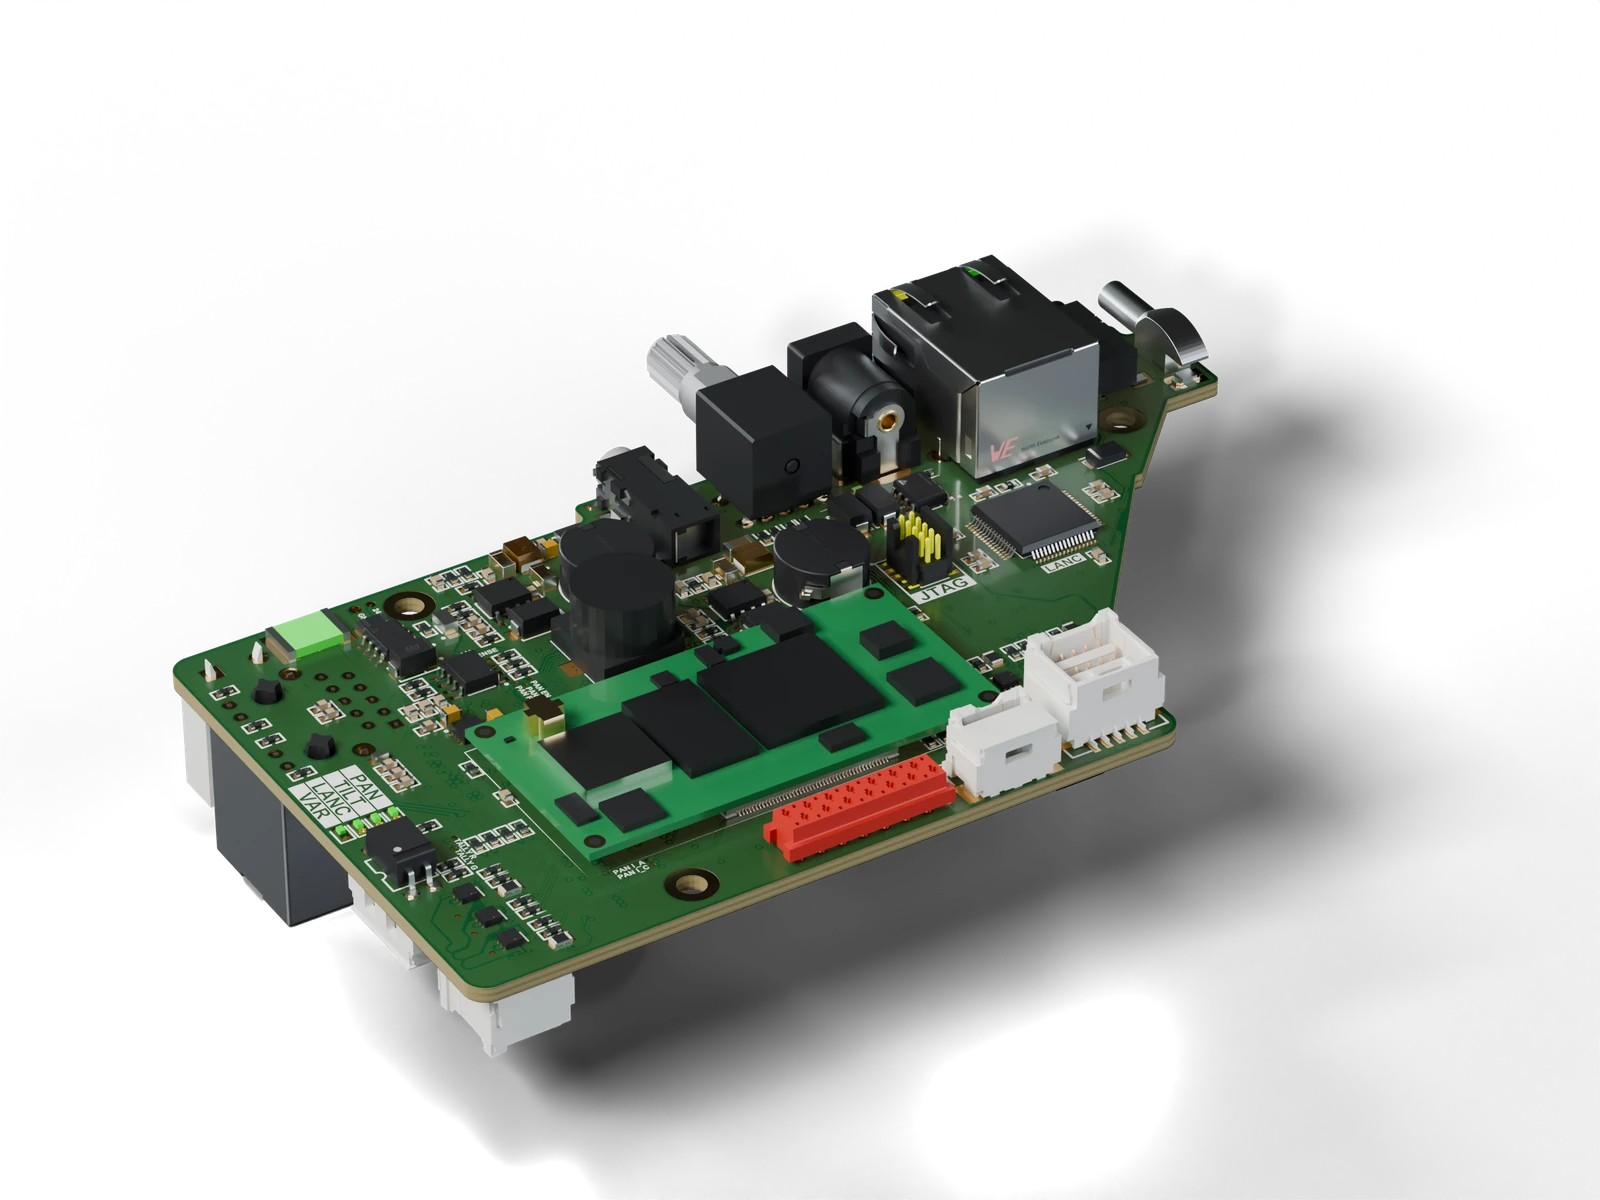
A remote-controlled robot that pans and tilts a camera of up to 5 kg for live production. We designed its main controller board, which handles motion, lens control, camera power and networking.

Client
Broadcast equipment manufacturer
Scope
Hardware, bring-up firmware and Ethernet bootloader
Timeline
6 months
Delivered
Board design, bring-up firmware, bootloader and manufacturing package

The challenge

Every function of the robot on one board

The client builds motorized camera systems for broadcast and live production. Their camera robot lets one operator move a camcorder, box camera or DSLR remotely, as if it were a dedicated PTZ camera, and the whole robot had to run from a single board.

That board had to drive both motion axes smoothly, control lenses from several makers, power the camera, provide networking for it and connect to lifts and dollies over CAN, all inside a compact, lightweight head.

What we built

One main board for motion, lens control, power and networking

Hardware

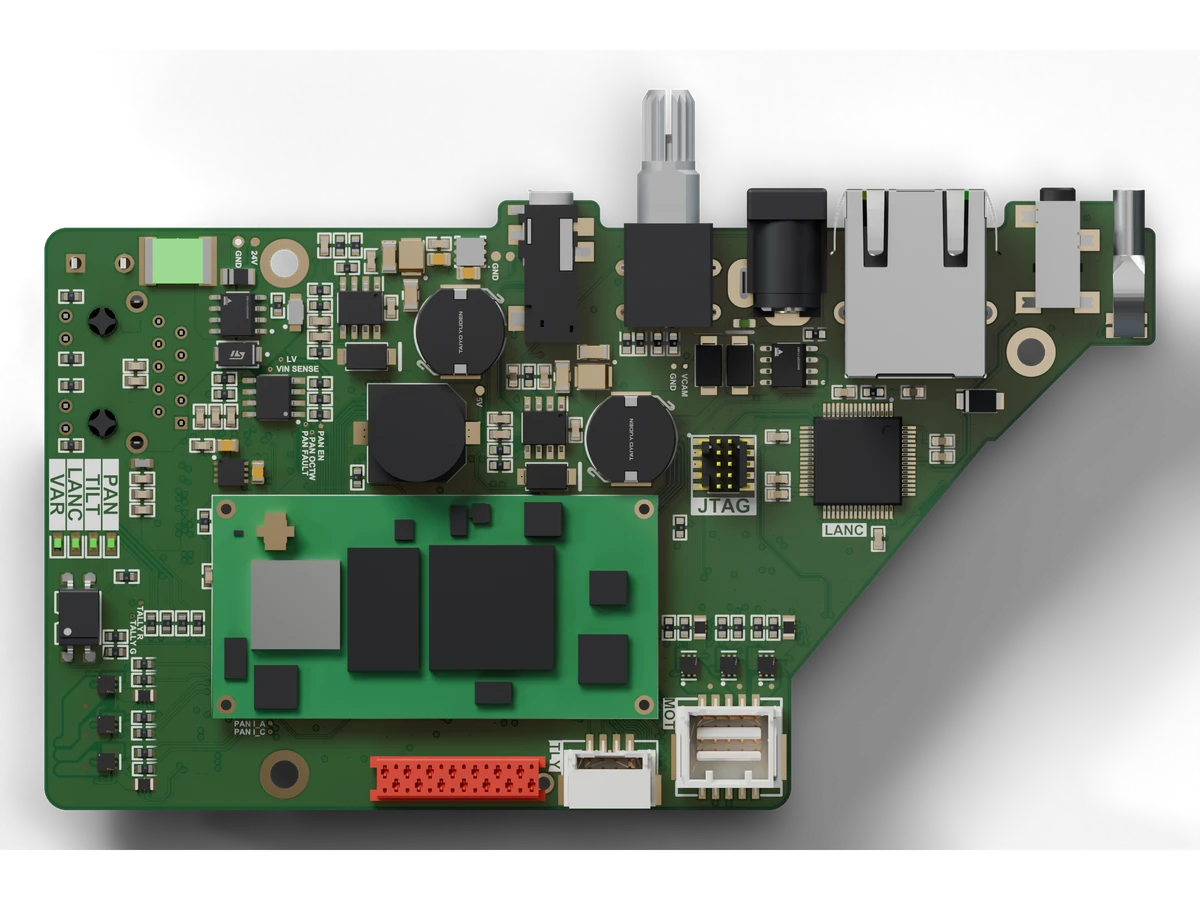
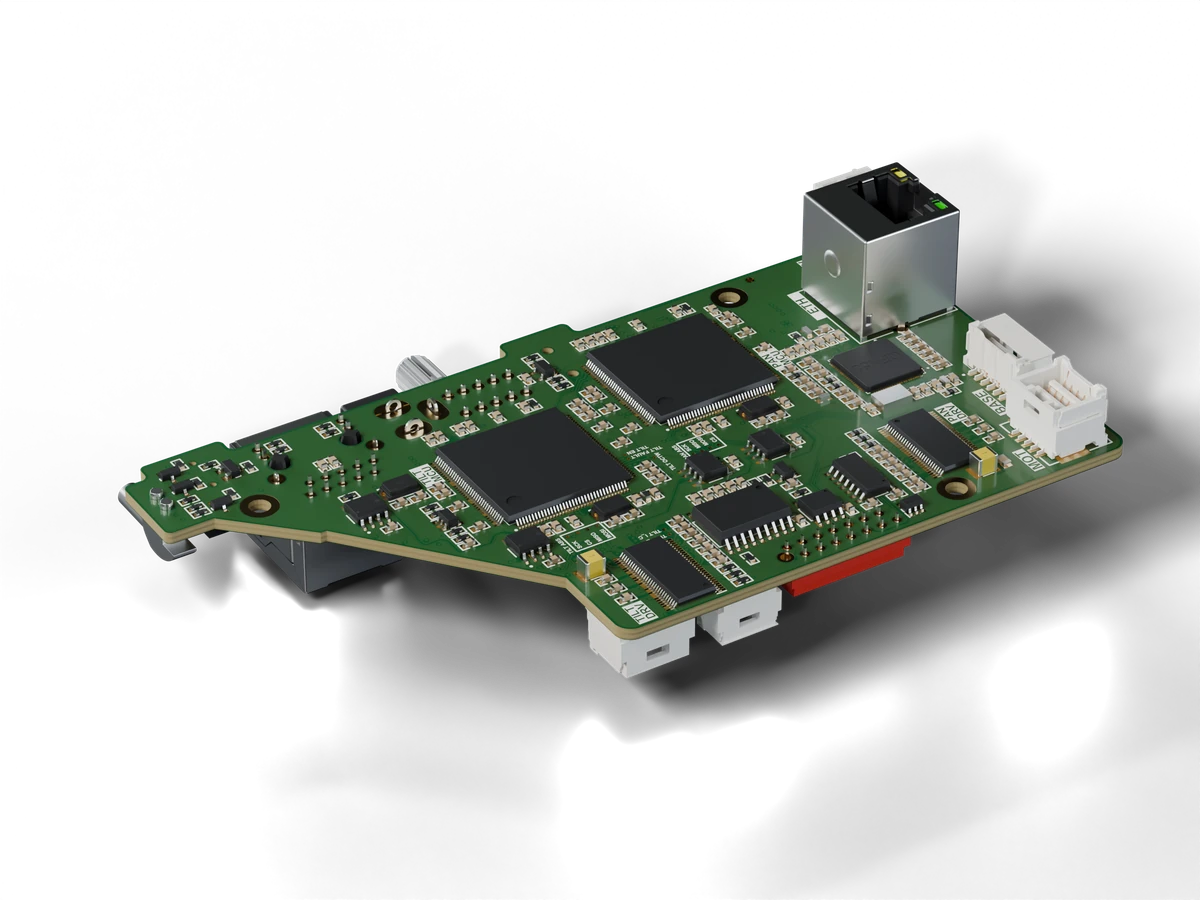
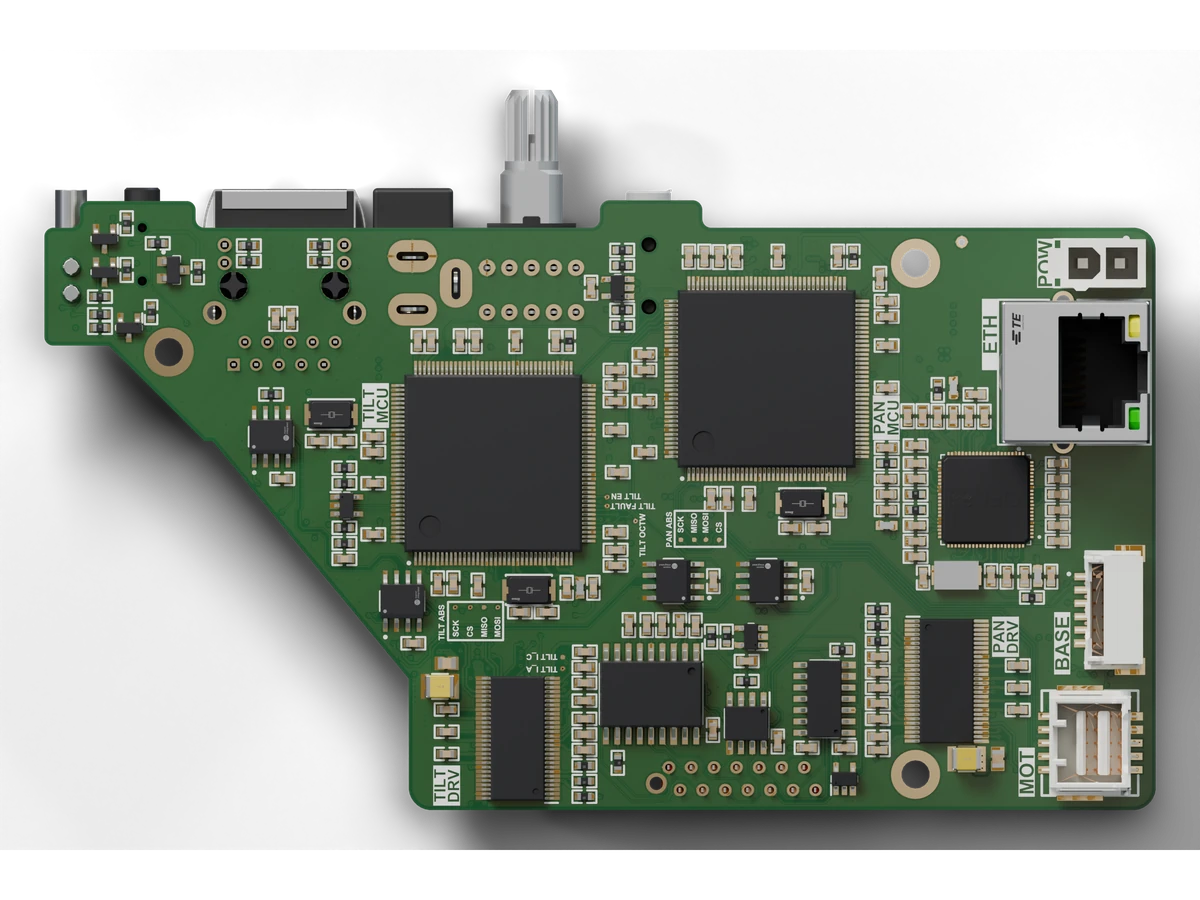
Main controller board

The robot's main board, from the motor drives to the camera power supply.

  • Pan and tilt motor control from 0.01 to 30°/s
  • Lens control for Canon and Fujinon lenses, external focus motors and LANC
  • Selectable camera power output from 7.4 to 24 V, up to 50 W
  • Built-in gigabit Ethernet switch with a port for the camera
  • CAN for camera lifts and dollies
  • 24 V power input

Firmware

Bring-up firmware and bootloader

Firmware to bring up and test the new hardware, plus an Ethernet bootloader for updates.

  • Bring-up and test code for every interface
  • Ethernet bootloader for firmware updates
  • A tested base for the client's application firmware

Delivery

Ready to manufacture

A production-ready design, refined over two hardware iterations.

  • Schematic and PCB layout
  • Prototype bring-up and testing
  • Manufacturing files
  • Two hardware iterations

Result

A camera robot on the market

  • On the market as part of the client's camera robot.
  • One board for motion, lens control, camera power and networking.
  • Two hardware iterations from the first prototype to the production design.
  • Six months from the start of the project to the production design.

Your project

Have something similar in mind?

Tell us what you are building and we will come back with questions and next steps.